
www.intralogisticsmag.com
02
'26
Written on Modified on
Integration of robotic control systems in high-speed intralogistics manipulators
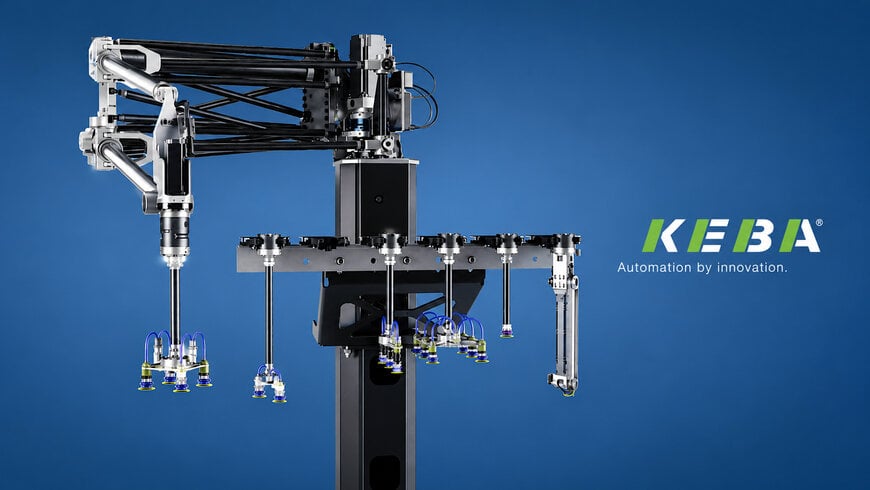
Cognibotics has implemented the KEBA KeMotion automation platform to optimize the energy efficiency and cycle path simulations of its hybrid kinematic robot.
www.keba.com
Application area: Intralogistics and material handling
Industry sector: Industrial automation
Cognibotics and KEBA Industrial Automation have partnered to integrate an advanced robotic control platform into a high-speed hybrid kinematic manipulator designed for intralogistics applications. This cooperation addresses the requirements for rapid pick-and-place operations, low energy consumption, and precise system simulation in material handling environments.
Operational challenges in dynamic intralogistics
Automating material handling in dynamic environments requires robotic systems capable of high cycle rates and extensive reach. Traditional robotic architectures often encounter limitations regarding thermal dissipation, energy consumption, and kinematic inertia during rapid acceleration and deceleration phases. To address these limitations, Cognibotics designed the Hybrid Kinematic Manipulator, an architecture optimized to achieve high throughput while maintaining structural stability and energy efficiency.
Technical architecture and control platform
The mechanical design centralizes servomotors and gears within the core structure to minimize moving mass. Utilizing carbon fiber arms and aluminum joints, the mechanical system reduces kinetic inertia. To control this hybrid parallel-serial kinematic configuration, Cognibotics deployed the KeMotion control system from KEBA.
Operating on the Kemro X industrial automation platform, this solution unifies machine control, robotics, and process technologies within a singular environment. The control architecture provides open development interfaces, allowing the integration of custom kinematic algorithms and proprietary operational parameters.
Simulation and deployment results
The unified control platform enabled digital modeling and simulation of the robot behavior prior to physical implementation. This simulation capability allowed engineers to evaluate operational paths and load capacities without mechanical risk, accelerating the commissioning phase.
The integrated system achieves over 2000 cycles per hour within a 10-square-meter working area, supporting a maximum payload capacity of 7.5 kg and a physical reach of 1800 mm. The reduction in moving mass combined with optimized trajectory control reduces energy losses and thermal emissions during continuous pick-and-place operations.
Edited by Sucithra Mani, Induportals editor – adapted by AI.
www.keba.com
